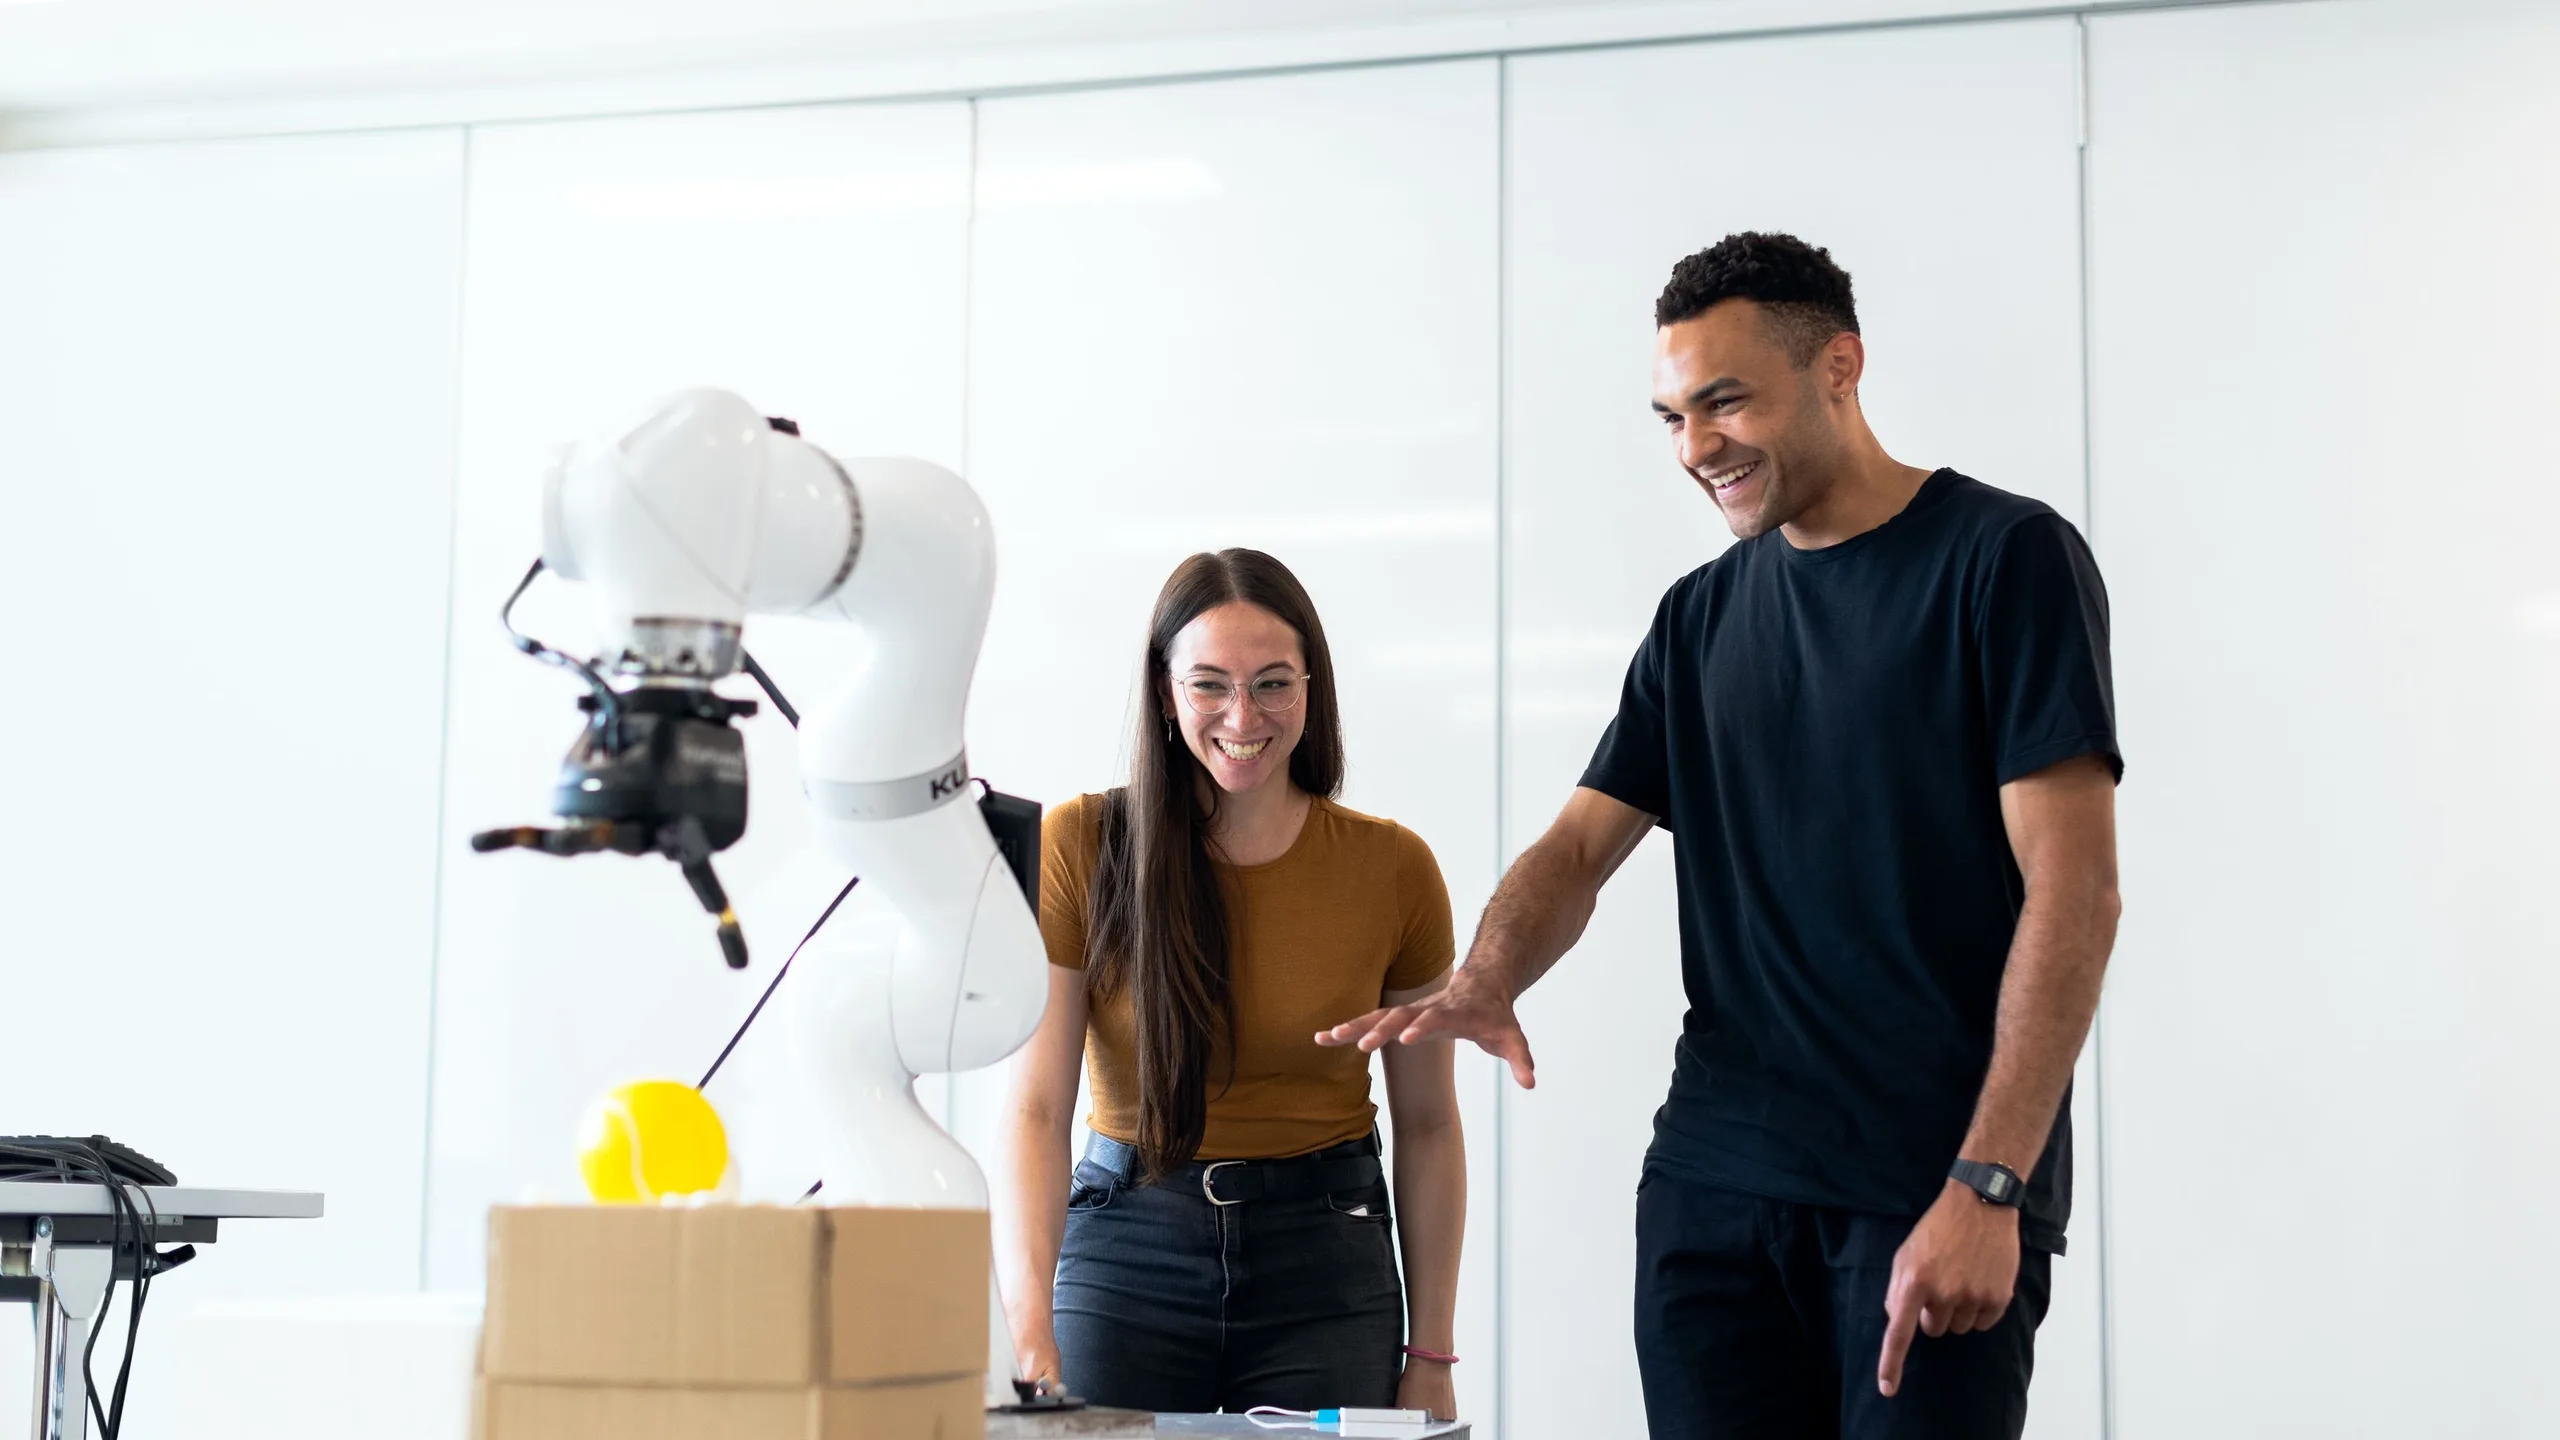
Two engineers examine a white robotic arm and gripper beside a cardboard box in a bright laboratory.

Robotics and Autonomy

Robotics connects computing to a machine that moves, observes, or manipulates the physical world. Autonomy describes how a system carries out a defined task with a particular degree of human involvement under stated conditions. The useful question is what the system can accomplish in that setting and how the evidence supports the claim.

This category introduces four guides for engineers, researchers, technical leaders, and industrial partners. They examine platform choices, the distribution of computing, human intervention, and the connection between perception, planning, and action. Together they help frame a bounded study around the physical task rather than a broad label such as fully autonomous.

Explore The Four Guides

Robots Drones and Autonomous Vehicles

A fixed manipulator, an aerial platform, and a ground vehicle offer different access and physical capabilities. The guide compares them through an inspection planning example, considering the required observation, payload, environment, and completion evidence. It explains why movement or remote operation alone does not establish a useful autonomous task.

Edge and Fleet Intelligence

Some computations belong near the equipment, while others need a view across several machines. Learn how local perception, shared task assignment, and central analysis can be divided. A mobile inspection example examines delayed communication, inconsistent shared state, constrained computing resources, and controlled software updates.

Human Intervention

Human involvement needs a defined trigger, an understandable view of the situation, effective authority, and enough time to respond. A blocked robot task illustrates the differences between a clarification, a pause, remote operation, and physical recovery. The guide includes the transfer back to the system and how intervention burden can be evaluated.

Perception Planning and Action

A perception result becomes useful only through its relationship to a physical task. A bin picking example follows an object estimate into candidate selection, motion, and outcome observation. The guide explains interface assumptions, uncertainty, partial completion, and why strong component scores do not establish successful integrated behavior.
Describe The Task and Operating Conditions

Name the work to be completed, the physical area, the objects involved, and the conditions examined. State where people participate and what changes the system may request. A robot that performs one transfer in a prepared setup has demonstrated a narrower capability than one that completes varied tasks amid changing equipment and demand.

Keep operating scope visible in the evaluation. Lighting, surface conditions, object variation, communication, and access can affect different platforms in different ways. A comparison should record those conditions and the human preparation needed, rather than treating every successful run as evidence for all environments.

Connect Local Behavior To Shared Responsibilities

Perception and task execution

The robot needs appropriately timed evidence about relevant objects, its own state, and the surrounding workspace. Planning needs to account for the platform’s actual physical capabilities. The executing controller then carries out its assigned behavior through a defined interface, with the equipment’s protective arrangements maintained.

Shared knowledge does not transfer authority automatically

A fleet service may recommend an assignment while the receiving platform decides whether it can accept it under its current conditions. A shared map, model, or task record can be incomplete or outdated. Define who owns each decision and how a disagreement is resolved without assuming that every component has an identical current view.

Evaluate The Integrated Task

Use a relevant baseline and an independent observation of completion. Include unresolved tasks, recovery effort, and operator work alongside completion time. Simulation can exercise planning logic and variations, but physical measurements add equipment response, sensing limitations, and real interface timing. Keep those kinds of evidence distinct when reporting a result.

Robotics and Distributed Intelligence owns research on embodied task execution and coordination. Identification and Sensing contributes observation and state evidence. AI Decisions and Control contributes bounded planning and decisions, while assurance and security address requirements across the arrangement. Specialist detail belongs with its corresponding research program.

Choose The Guide For Your Question


Start with the platform guide when deciding how equipment could access a task. Choose Edge and Fleet Intelligence when deciding where computation and coordination belong. Read Human Intervention for unresolved conditions and recovery, and Perception Planning and Action when investigating how component behavior affects a complete physical outcome.

Scroll to Top