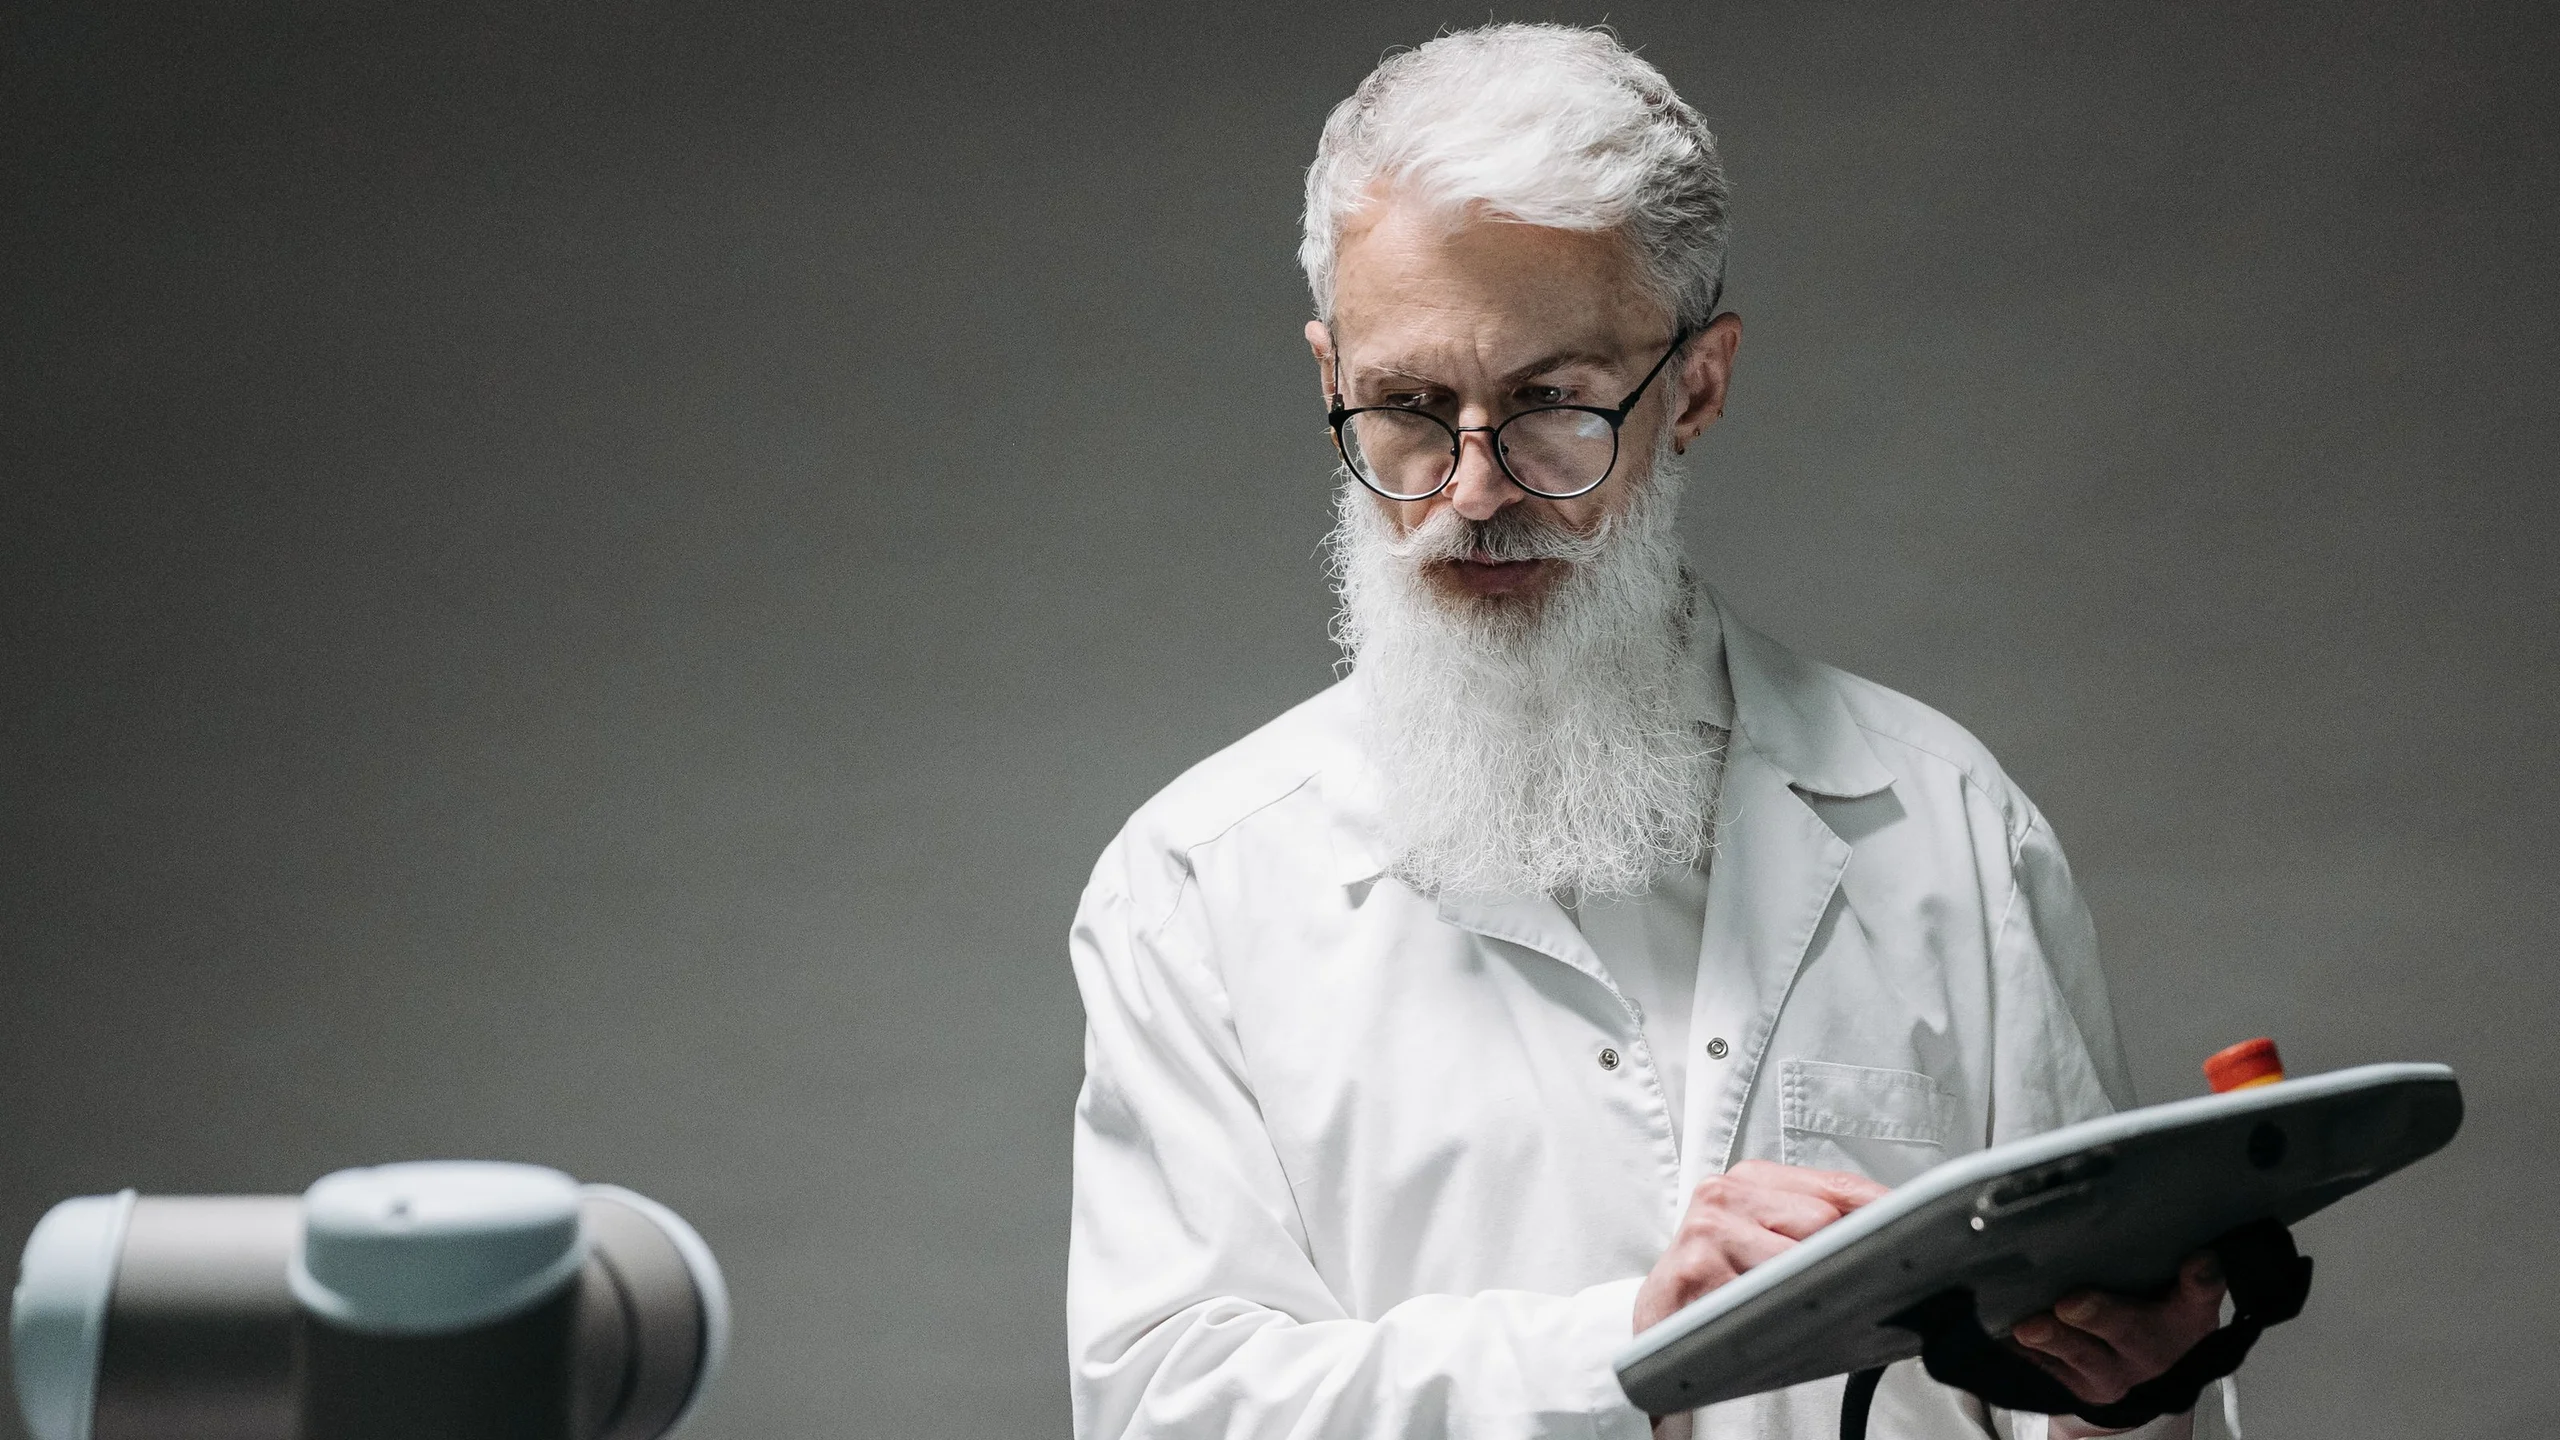
A laboratory researcher uses a handheld robot interface beside a robotic arm in an indoor workspace.

Human Intervention

Human intervention is a defined change in how a person participates in a system’s task. It may involve clarifying a target, approving a proposal, pausing work, taking direct control, or organizing physical recovery. A person’s presence in the workflow does not by itself establish that intervention is timely or effective.

The design needs to explain when help is requested, what the person can see, what authority transfers, and how the system returns to its next state. These questions connect the interface to the physical task. They are especially important when a robot encounters conditions that its current observations or approved behavior cannot resolve.

A Blocked Task Example

Consider a proposed study in which a mobile robot carries an inspection sensor toward a planned observation point. An unexpected obstruction prevents the planned approach. The system can explain the unresolved condition and request a defined form of assistance under the study’s operating arrangements.

The person might identify an alternative approved observation point or decide that the task should remain incomplete. Direct remote operation or physical recovery would involve different authority and preparation. The example is an evaluation scenario, not a procedure for moving around obstructions or entering a robot workspace.

Define What Kind Of Help is Needed

Clarification and task review

A clarification can resolve an ambiguous target or instruction without transferring movement control. Show which interpretation is uncertain and what decision the person is being asked to make. Avoid a generic assistance message that leaves the reviewer to reconstruct the entire mission before understanding the question.

Approval of a proposal

Approval concerns a specific proposed change and the context supporting it. The interface should identify the task, equipment, relevant evidence, and consequences. A later revision to the destination or requested behavior should be handled under the agreed approval rules rather than borrowing a decision made for an earlier proposal.

Direct control or physical recovery

Remote operation changes who issues movement requests, while physical recovery involves people and equipment at the site. These are different modes and may require different capabilities and responsibilities. Keep them separate from ordinary task clarification, and retain the existing equipment and site arrangements governing their use.

Make control ownership explicit

The person and system need a consistent understanding of which component currently owns the task and which commands can be accepted. A screen showing manual mode is insufficient if another service can still submit competing requests. Evaluate the accepting interfaces and mode transitions, not only the visible button labels.

Request Intervention While It Can Help

Define triggers in relation to the task and evidence. The robot may be unable to establish its target, reconcile conflicting observations, or continue within the permitted behavior. Trigger design should avoid both silent unresolved work and unnecessary requests for every minor variation.

A human response takes time. Detection, notification, queueing, interpretation, and action all contribute. If the physical situation changes faster than the person can understand and influence it, a request for approval is not an adequate substitute for the system’s required local behavior. The response design must fit the actual available time.

Provide A Useful View Of The Situation

Show the intended task, current mode, last confirmed state, observation times, and why progress is unresolved. A camera view can be helpful while leaving important areas unseen. A map can be out of date. Present those limits so the person can distinguish what is observed from what is inferred or missing.

For the blocked task example, the reviewer needs to know which inspection point remains unobserved and why. A general image of the aisle may not explain whether the robot has completed any part of the task. Keep the request tied to evidence and the specific decision being offered.

Define Behavior While Waiting

The system needs an agreed response while assistance is unavailable. Depending on the equipment and task, that could mean preserving an unresolved task state and following an established local operating arrangement. This guide does not prescribe one universal stop or hold behavior, because the physical consequences vary by system.

Do not treat lack of response as automatic consent unless an explicitly designed and evaluated workflow gives that event a defined meaning. Record escalation, reassignment, and expired requests so the system does not continue waiting for a person who no longer owns the case. Evaluate the situation under representative staffing and workload.

Return Responsibility Deliberately

After intervention, establish what changed and which conditions now support the next step. A person may have selected a different target, corrected an association, or organized physical recovery. Those events need to be reflected in the task state before the system resumes or closes the work.

The return should preserve the identity of the active plan and any unresolved effects. Ending remote control does not necessarily mean the original autonomous task can continue. A confirmed mode transition and appropriate current evidence are needed to make the receiving component’s responsibility clear.

Evaluate The Person and System Together

Compare interface designs using defined scenarios and participants whose preparation matches the intended role. Assess time to understand the request, incorrect interpretations, completed interventions, unresolved cases, and task recovery. Include the cognitive and coordination work required, not only the number of button presses.

Test notification delay, stale observations, multiple simultaneous requests, unavailable staff, and interrupted handoffs within a controlled study. Measure workload as task demand changes. An interface that works with one researcher attending one robot may not support several machines sharing an operator’s attention.

Use Intervention Evidence To Improve The Task Design


Frequent requests may indicate weak perception, ambiguous task definitions, poor interfaces, or unrealistic operating scope. Review their causes before assuming that the solution is simply more operator training. Human corrections can inform later research, but they should not silently become labels proving that the system’s original output was correct.

Report the kinds of intervention examined, the available context, timing, participant preparation, and failures. The useful result is evidence that the human contribution works under those conditions, with clear limits on what broader supervision or autonomous operation has been established.

Scroll to Top